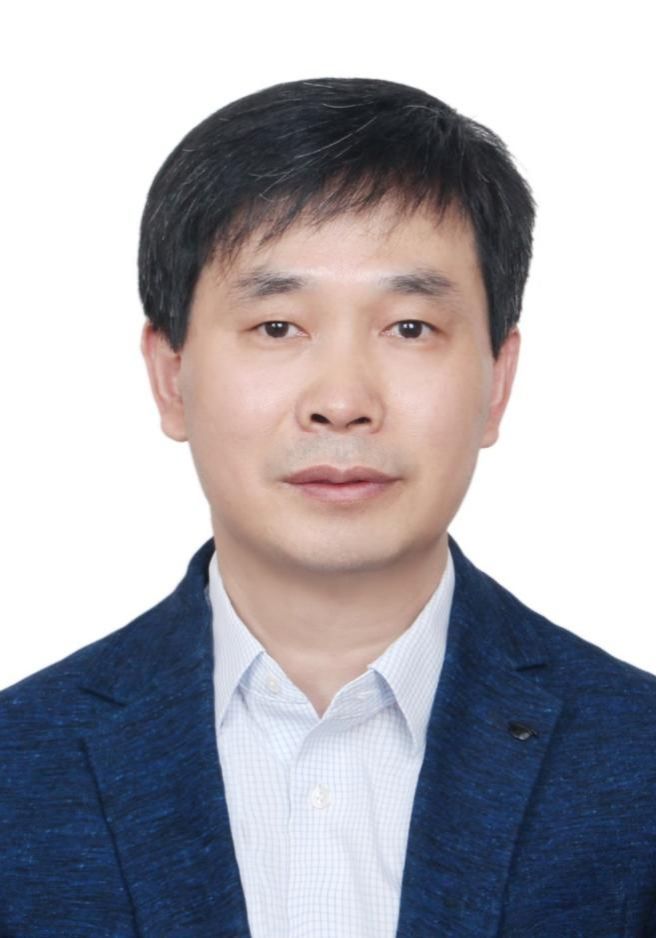
Wang Aihui is a professor at Zhongyuan University of Technology and completed postdoctoral research at Bournemouth University in the United Kingdom from 2014 to 2015. Wang leads the Control Engineering team recognized by Henan Province for excellence in graduate supervision, has been named an Outstanding Teacher in Henan's Education, Science, Culture, Health and Sports System, and holds Category C high-level talent status in Henan Province. Wang leads the Henan International Joint Laboratory for Intelligent Biomimetic Robotics and the University's Electronic Information discipline, which was designated a Henan Provincial Key Discipline in the latest selection round. He also heads the undergraduate programs in Automation and Robotics Engineering and serves as Vice President of the Henan Robotics Industry Association. He serves as an expert reviewer for projects funded by the National Key R&D Program of China and the National Natural Science Foundation of China, as well as major special projects and key R&D projects in Henan Province.
His awards include one Second Prize of the Henan Science and Technology Progress Award, one First Prize and one Second Prize of the Henan Provincial Department of Education Scientific and Technological Achievement Award, four First Prizes for Outstanding Academic Papers from the same department, and one First Prize from an industry association. He has published more than 120 papers indexed in SCI or EI and three academic monographs. He has also been granted nine invention patents. He has led one subproject under the National Key R&D Program of China, one Henan Key R&D Project, and four other projects at the provincial or ministerial level. As a key contributor, he has participated in six projects funded by the National Natural Science Foundation of China, one major international cooperation project, two Europe–Asia cooperation projects, more than ten provincial or ministerial projects, and three projects at the national or regional level in Japan.
Education Experience:
(1) September 1997–June 2001, Bachelor's degree in Industrial Automation, Zhengzhou University
(2) September 2001–June 2004, Master's degree in Control Theory and Control Engineering, Zhengzhou University
(3) October 2009–September 2012, Ph.D. in Electronic Information, Tokyo University of Agriculture and Technology, Japan
(4) October 2014–September 2015, Postdoctoral research at Bournemouth University, United Kingdom
Research Directions:
(1) Intelligent actuation and bionic robotics
(2) Networked collaborative manufacturing integration technologies
Academic Research Projects:
(1) National Key R&D Program (subproject), Development of Supply/Marketing/Service Collaborative Technologies Based on the Full Value Chain (SQ2020YFB170004), November 2020–October 2023, RMB 4.02 million, Principal Investigator.
(2) Henan Key R&D Program: Research and Application of Key Human–Robot Integration Technologies for Lower-Limb Rehabilitation Robots (241111312000), January 2024–December 2026, RMB 1.9 million, Principal Investigator.
(3) Ministry of Science and Technology International Science and Technology Cooperation Project (subproject): Research on an Eco-Friendly System Integrating Fuel Cells and Peltier Cooling for Energy Conservation and Greenhouse Gas Reduction (2010DFA22770), January 2011–December 2013, RMB 1.26 million, ranked third.
(4) NSFC Key Project: Key Actuation and Control Technologies for Micro-/Nano-Manipulation Robots for Precision High-Speed Processing (U1813201), January 2019–December 2022, RMB 2.89 million, collaborating institution ranked second.
(5) NSFC General Program: Constrained Multimodal Multi-Objective Co-Evolutionary Methods Based on Subspace Classification Perception and Their Applications (62373389), January 2023–December 2026, RMB 500,000, ranked second.
(6) NSFC General Program: Nonlinear Robust Control Technology for Smart Material Actuators in Micro-/Nano-Manipulation (62073297), January 2021–December 2024, RMB 590,000, ranked second.
(7) NSFC General Program: Research and Application of Advanced Safe Process Control Systems for Maintaining Production Functions During Disasters (61074022), January 2011–December 2013, RMB 380,000, ranked third.
(8) NSFC Young Scientists Fund: Research on Control for Maintaining Safe Production Functions Based on Decentralized Cooperative Communication (61304115), January 2014–December 2016, RMB 250,000, ranked second.
(9) NSFC Young Scientists Fund: Real-Time Grasping Motion Planning and Optimization for Manipulation Robots Interacting with Complex Environments (61803396), January 2019–December 2021, RMB 240,000, completed, third contributor.
(10) Henan Key R&D Program: Key Technologies and Applications of Precision High-Speed Micro-/Nano-Processing Robots (231111221600), January 2023–December 2025, RMB 1.9 million, ranked second.
(11) Henan Science and Technology Research Project: Micro-/Nano-Control Technology for Smart Material Actuators with Complex Dynamic Hysteretic Nonlinearities (202102210097), January 2020–December 2021, RMB 100,000, Principal Investigator.
(12) Henan Natural Science Foundation Project: Operator-Theory-Based Nonlinear Robust Control of Robotic Arms with Human-Arm-Like Viscoelastic Characteristics (162300410345), January 2017–December 2018, RMB 100,000, Principal Investigator.
Awards:
(1) Second Prize of the Henan Science and Technology Progress Award: Upper-Limb Rehabilitation Robot Control Technology and Applications Integrating Multi-Joint Viscoelasticity and Human Movement Intention, Henan Provincial People's Government, December 2023, ranked first.
(2) First Prize of the Henan Department of Education Scientific and Technological Achievement Award: Upper-Limb Rehabilitation Robot Control Technology Integrating Multi-Joint Viscoelasticity and Human Movement Intention, March 2023, ranked first.
(3) First Prize of the China General Chamber of Commerce Science and Technology Award: Home Health Monitoring Technology for Older Adults Based on Multi-Objective Artificial Bee Colony Algorithms, December 2021, ranked third.
(4) First Prize of the Henan Department of Education Outstanding Scientific Paper Award: "Robust nonlinear multivariable tracking control design to a manipulator with unknown uncertainties using operator-based robust right coprime factorization," May 2019, ranked first.
(5) First Prize of the Henan Department of Education Outstanding Scientific Paper Award: “Characteristic analysis and modeling of a miniature pneumatic curling rubber actuator,” May 2018, ranked first.
Representative Papers:
(1) A. Wang, H. Yu, and S. Cang, Bio-inspired robust control of a robot arm-and-hand system based on human viscoelastic properties, J. Franklin Institute, 345(4): 1759–1783, 2017.
(2) N. Hu, L. Ding, A. Wang, W. Zhou, C. Zhang, B. Zhang and R. Yin, Comprehensive modeling of corkscrew motion in micro-/nano-robots with general helical structures, Nature Communications, doi:10.1038/s41467-024-51518-z, 2024.
(3) A. Wang and M. Deng, Robust nonlinear multivariable tracking control design to a manipulator with unknown uncertainties using operator-based robust right coprime factorization, Transactions of the Institute of Measurement and Control, 35(6): 788–797, 2013.
(4) N. Hu, A. Wang, and Y. Wu, Robust adaptive PD-like control of lower limb rehabilitation robot based on human movement data, PeerJ Computer Science, doi:10.7717/peerj-cs.394, 2023.
(5) J. Ren, H. Li, A. Wang, K. Saso and L. Meng, Radar-based gait analysis by Transformer-liked network for dementia diagnosis, Biomedical Signal Processing and Control, doi:10.1016/j.bspc.2024.105986, 2024.
Representative Works and Achievements:
(1) Invention Patent: Human-Body-Size-Adaptive Upper-Limb Exoskeleton Mechanism and Machine Learning Control Method (ZL201911305041.0), October 28, 2022, first inventor.
(2) Invention Patent: A Novel Flexible Exoskeleton Material and Control Method (ZL201911142013.1), August 15, 2023, first inventor.
(3) Invention Patent: A Design Method for an Exoskeleton Device (ZL201911142027.3), August 22, 2023, first inventor.
(4) Monograph: Design of Nonlinear Control Systems Based on Operator Theory (ISBN 978-7-5180-7913-1), China Textile & Apparel Press, October 2020, first editor-in-chief.
(5) Monograph: Nonlinear Operator Control and Its Applications (ISBN 978-7-5180-5404-6), China Textile & Apparel Press, September 2018, second editor-in-chief.
Contact:
Email: a.wang@zut.edu.cn