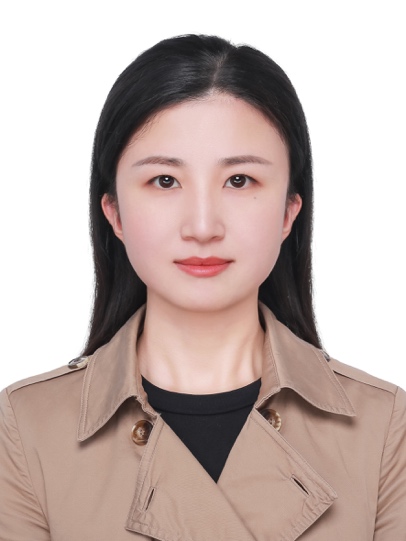
Zhang Shuhua is a lecturer at Zhongyuan University of Technology and a postdoctoral researcher at Beijing Institute of Technology. She holds a Ph.D. from Nanjing University of Science and Technology. She is dedicated to research in complex nonlinear systems, networked control systems, tracking control of unmanned vehicles/surface vessels, data-driven control, and related fields. She has published more than 15 journal/conference papers. She has led one National Natural Science Foundation of China Young Scientists Fund project (Category C), one Henan Provincial Science and Technology Research Project, and one Jiangsu Provincial Postgraduate Research Innovation Program project; she has also participated in multiple national-level research projects, including the National 973 Program and National Natural Science Foundation projects. Supported by the China Scholarship Council (CSC), she visited the University of Cyprus for one year and established a collaborative relationship with Professor Themistoklis Charalambous. She has served as a reviewer for multiple international journals/conferences, including IEEE Transactions on Systems, Man, and Cybernetics: Systems, IEEE Transactions on Automation Science and Engineering, International Journal of Systems Science, Neurocomputing, and IEEE Conference on Decision and Control. She has received one First Prize of the Science and Technology Progress Award of the Chinese Association of Automation, the Shandong Provincial Excellent Master's Thesis Award, and the title of Excellent Master’s Graduate of Qingdao University of Science and Technology. She has guided students in electronic design competitions, winning two provincial awards.
Education and Research Work Experience:
1. 2025.01-present, Lecturer, School of Automation and Electrical Engineering, Zhongyuan University of Technology
2. 2025.10-present, Postdoctoral researcher, School of Automation, Beijing Institute of Technology
3. 2020.09-2025.01, Nanjing University of Science and Technology, Control Science and Engineering, Ph.D.
4. 2023.09-2024.10, University of Cyprus, Control Science and Engineering, joint Ph.D. training
5. 2017.09-2020.06, Qingdao University of Science and Technology, Control Engineering, Master’s degree
Research Directions:
1. Data-driven control
2. Tracking control of unmanned systems (unmanned vehicles and unmanned surface vessels)
3. Nonlinear networked control systems
4. Distributed cooperative control and estimation
Academic Research Projects:
1. National Natural Science Foundation of China Young Scientists Fund (Category C): Data-Driven Secure Control of Nonlinear Networked Systems under Multiple Constraints, 2026.01-2028.12, Principal Investigator
2. Henan Provincial Science and Technology Research Project: Data-Driven Distributed Cooperative Control for Unmanned Surface Vessel Swarm Patrol in Complex Waters, 2026.01-2027.12, Principal Investigator
3. Zhongyuan University of Technology Natural Science Foundation Project: Research on Path Tracking Control Methods for Unmanned Surface Vessels in Complex-Water Patrol Tasks, 2026.01-2027.12, Principal Investigator
4. China Scholarship Council Project: Data-Driven Control of Networked Nonlinear Systems, 2023.09-2024.09, Principal Investigator
5. Jiangsu Provincial Postgraduate Research and Practice Innovation Program: Data-Driven Control of Nonlinear Systems under Cyberattacks, 2023.04-2024.03, Principal Investigator
Awards:
1. First Prize of the Science and Technology Progress Award of the Chinese Association of Automation, 1 item
2. Shandong Provincial Excellent Master's Thesis, 1 item
3. Excellent Master's Graduate Student of Qingdao University of Science and Technology, 1 item
4. Wanhua Chemical Scholarship, 1 item
5. Third Prize of the 14th "Huawei Cup" China Graduate Mathematical Contest in Modeling, 1 item
Representative Papers:
[1] Shuhua Zhang, Lifeng Ma*, Ronghu Chi, Hongjian Liu, Adaptive iterative learning control of discrete-time nonlinear networked systems: A two-description coding approach, IEEE Transactions on Systems, Man, and Cybernetics: Systems, 55(3):1684--1693, 2025.
[2] Shuhua Zhang, Lifeng Ma*, Xiaojian Yi, Data-driven control for nonlinear networked systems on basis of two-description coding scheme, IEEE Transactions on Automation Science and Engineering, 21(4):6721--6730, 2024.
[3] Shuhua Zhang, Lifeng Ma*, Xiaojian Yi, Model-free adaptive control for nonlinear multi-agent systems with encoding-decoding mechanism, IEEE Transactions on Signal and Information Processing over Networks, 8:1--13, 2022.
[4] Shuhua Zhang, Lifeng Ma*, Hongjian Liu, Encryption-decryption-based event-triggered consensus control for nonlinear multi-agent systems under DoS attacks, International Journal of Robust and Nonlinear Control, 34(1):132--146, 2024.
[5] Shuhua Zhang, Ronghu Chi*, Model-free adaptive PID control for nonlinear discrete-time systems, Transactions of the Institute of Measurement and Control, 42(10):1797--1807, 2020.
[6] Shuhua Zhang, Yu Hui, Ronghu Chi*, Juan Li, Nonholonomic dynamic linearization based adaptive PID-type ILC for nonlinear systems with iteration-varying uncertainties, International Journal of Systems Science, 51(5):903--921, 2020.
[7] Chen Hu, Shuhua Zhang*, Hongyuan Zhao, Lifeng Ma*, Jian Guo, Probability-guaranteed encoding-decoding-based state estimation for delayed memristive neutral networks with event-triggered mechanism, International Journal of Adaptive Control and Signal Processing, 38(8):2750--2770, 2024.
[8] Ronghu Chi*, Yu Hui, Shuhua Zhang, Biao Huang, Zhongsheng Hou, Discrete-time extended state observer based model-free adaptive control via local dynamic linearization, IEEE Transactions on Industrial Electronics, 67(10):8691--8701, 2020.
[9] Shuhua Zhang*, Lifeng Ma, Themistoklis Charalambous, Data-driven control for nonlinear automated vehicles with multi-description coding for handling data dropouts, 2024 63rd IEEE Conference on Decision and Control (CDC), Milan, Italy, 2024.
[10] Yuke Cheng, Yuanqing Xia, Shuhua Zhang*, and Hongjiu Yang. Dual-Loop Active Disturbance Rejection Control for Unmanned Surface Vehicles Under Wind Disturbance. In 2025 9th CAA International Conference on Vehicular Control and Intelligence (CVCI), Oct 2025.
[11] Lixiang Shi, Yuanqing Xia, Dongdong Yu, and Shuhua Zhang. Slope-Aware Path Tracking Control for Unmanned Vehicles Using Active Disturbance Rejection Control. In 2025 9th CAA International Conference on Vehicular Control and Intelligence (CVCI), Oct 2025.
[12] Shuhua Zhang, Yu Hui, and Ronghu Chi. Data-driven Adaptive Iterative Learning Control Based on a Local Dynamic Linearization. IEEE 7th Data Driven Control and Learning Systems Conference (DDCLS), 2018.
[13] Ronghu Chi, Shuhua Zhang, and Yu Hui. Model-free adaptive control based on local dynamic linearization. Chinese Control And Decision Conference (CCDC), 2018.
Contact:
Email: zhangshuhua@zut.edu.cn